
DexForce Technology
DexForce develops foundation models and integrated hardware to bring physical AI into the real world. Founded in 2021 in Shenzhen, the company is led by Prof. Kui Jia, with a research team that works across simulation and physical reality and has published results on robotics benchmarks including RoboTwin and WorldArena. The team draws members from Tsinghua, Peking, Fudan, Shanghai Jiao Tong, MIT, HKUST and CUHK. The full-stack matrix combines the DexVerse simulation engine, DexWorldModel, the EmbodiChain platform, DexSense vision sensors and the W1 Pro humanoid robot. Models are deployed into complex, unstructured environments rather than kept in the lab. Across 50+ industries in industrial manufacturing and commercial operations, every real-world task feeds back into the generative world models, a continuous flywheel between algorithmic advancement and practical utility.
Vision and Mission
Milestones
- An early research group applying AI to 3D vision and robot interaction
- 100+ papers, 20,000 citations
- Angel round from Songhe Capital, ZhenFund and others
- First Sim2Real perception kits delivered
- The 1+3 product line built on DexVerse ships
- Close to 100 Sim2Real perception kits delivered cumulatively
- Sim2Real-enabled dexterous manipulation released as a product-grade solution
- Deployment across automotive, home appliance and commercial service sectors
- First-generation KINGFISHER vision sensor launched
- Vision fusion solution released at product grade
- 50+ industries, 100+ customers, 1,500+ scenarios
- Volume production, with validated deployment in commercial service and industrial sites
- Engine-driven Sim2Real VLA, an approach that moves past the Scaling Law constraint
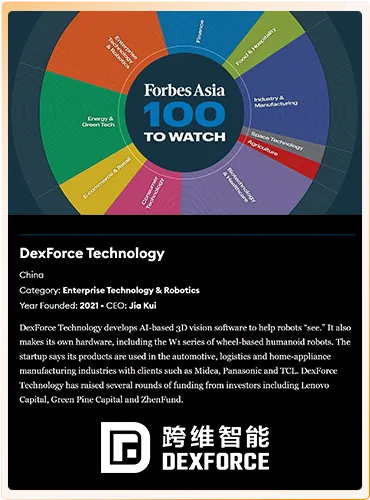
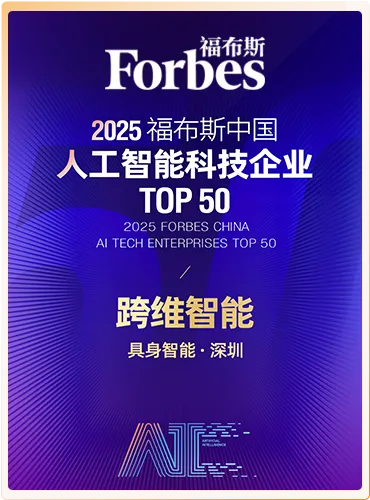
- Listed on Forbes annual rankings for a second year
- Embodied world model DexWorldModel, with the EmbodiChain toolchain open-sourced
- Dexterity-BEV, data infrastructure for physical AI
- Series B closed
- Physical Token economics proposed as a frame for the physical AI industry
- W1 Pro deployed at scale across industrial and commercial sites
- UNITAS, a task-native 3D world model, released and open-sourced
Partners




Honors & Awards