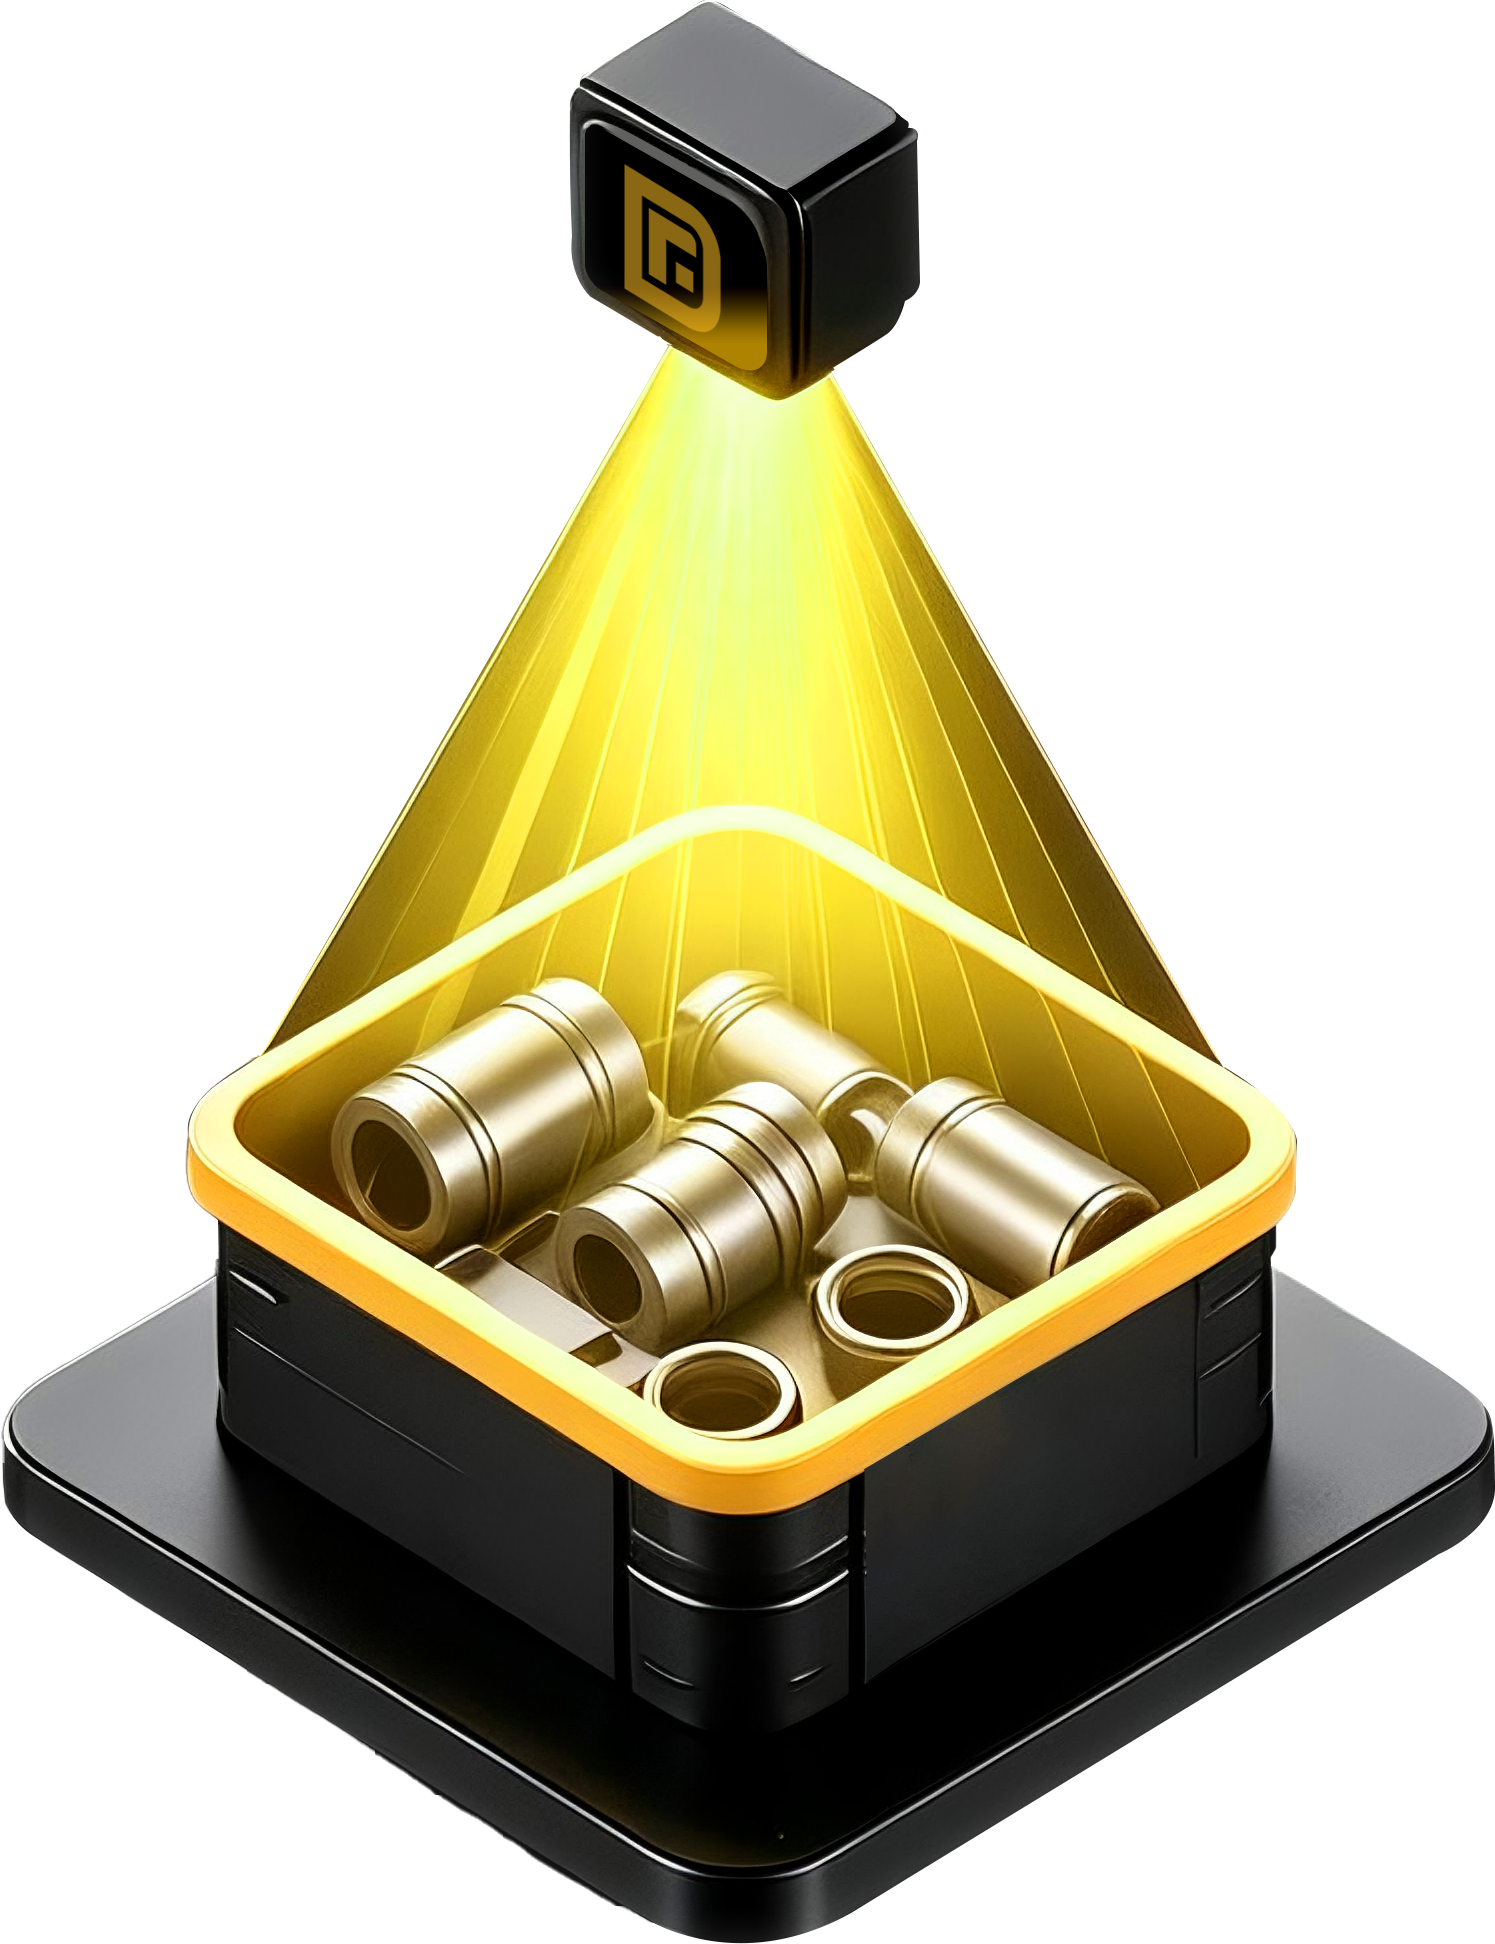
Unordered Part Recognition
Unordered Part Recognition
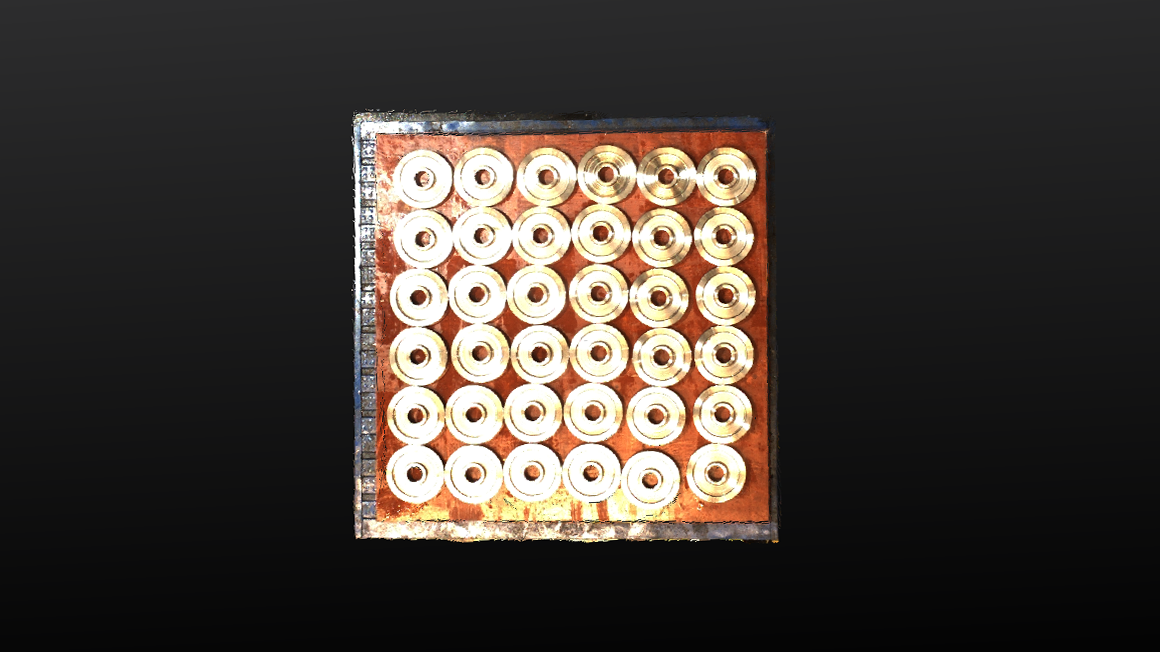
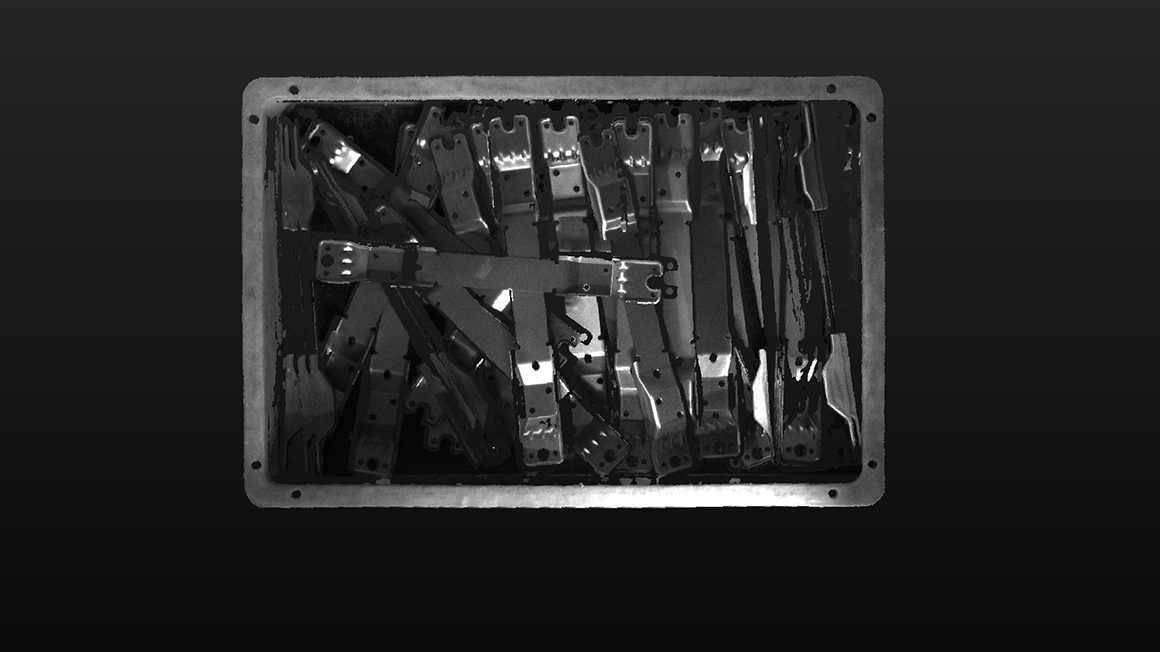
Recognizes randomly stacked parts, with no fixtures required.
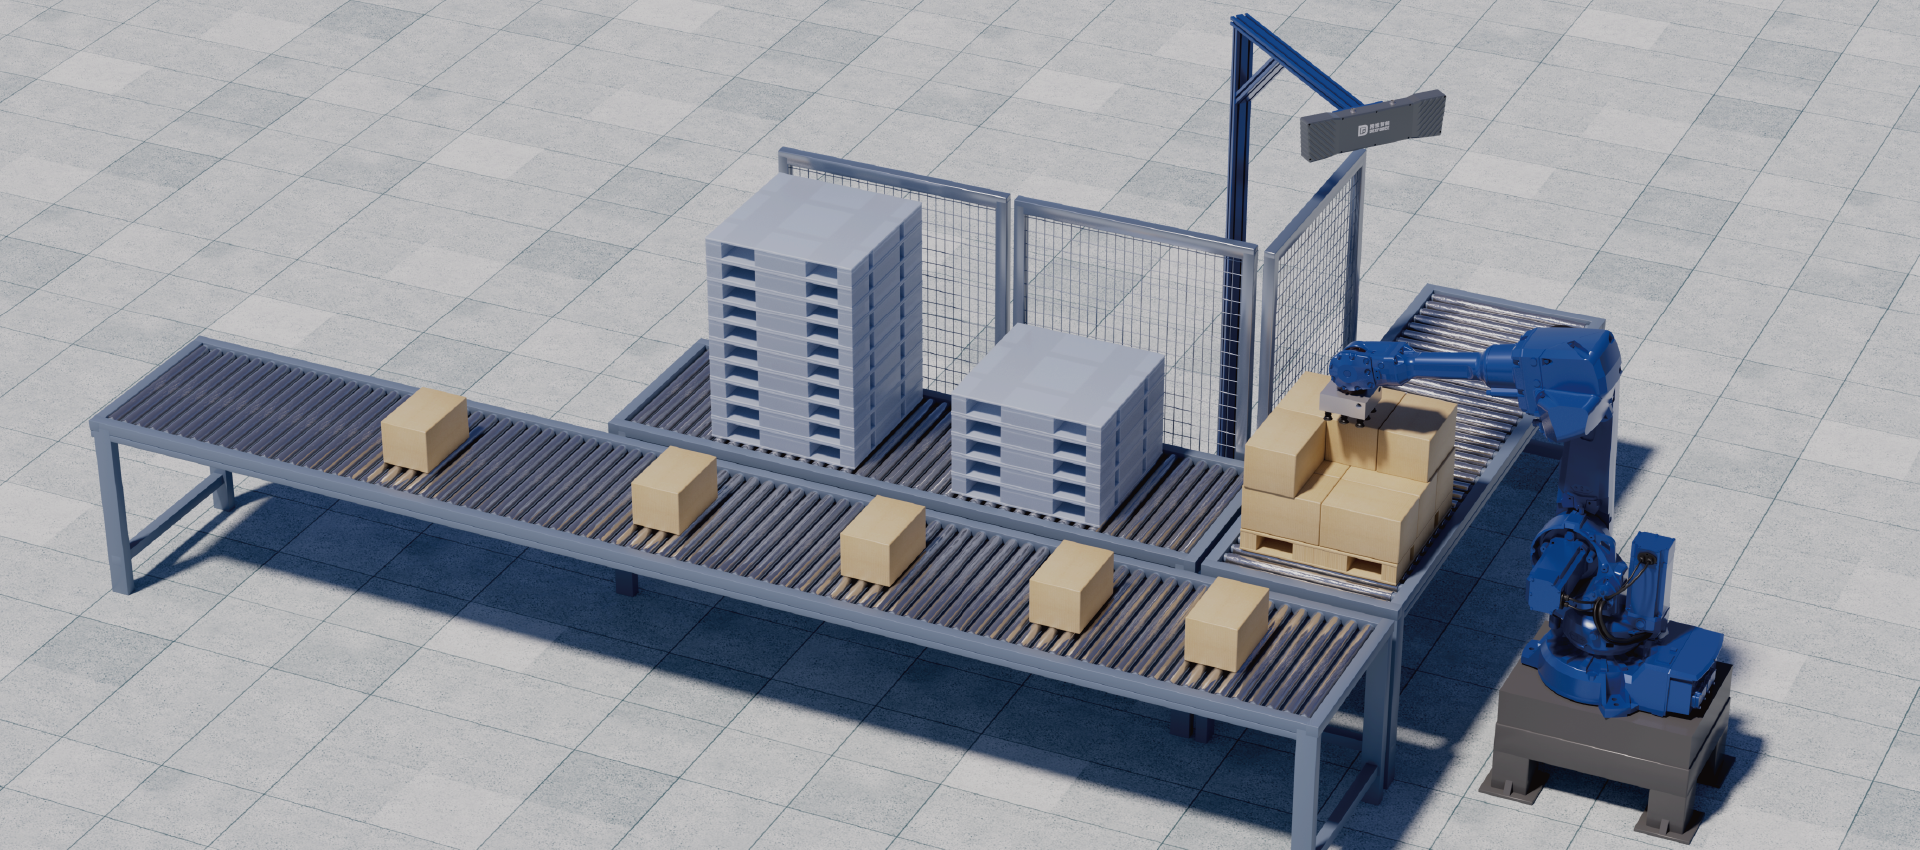
Recognizes randomly stacked parts, with no fixtures required.
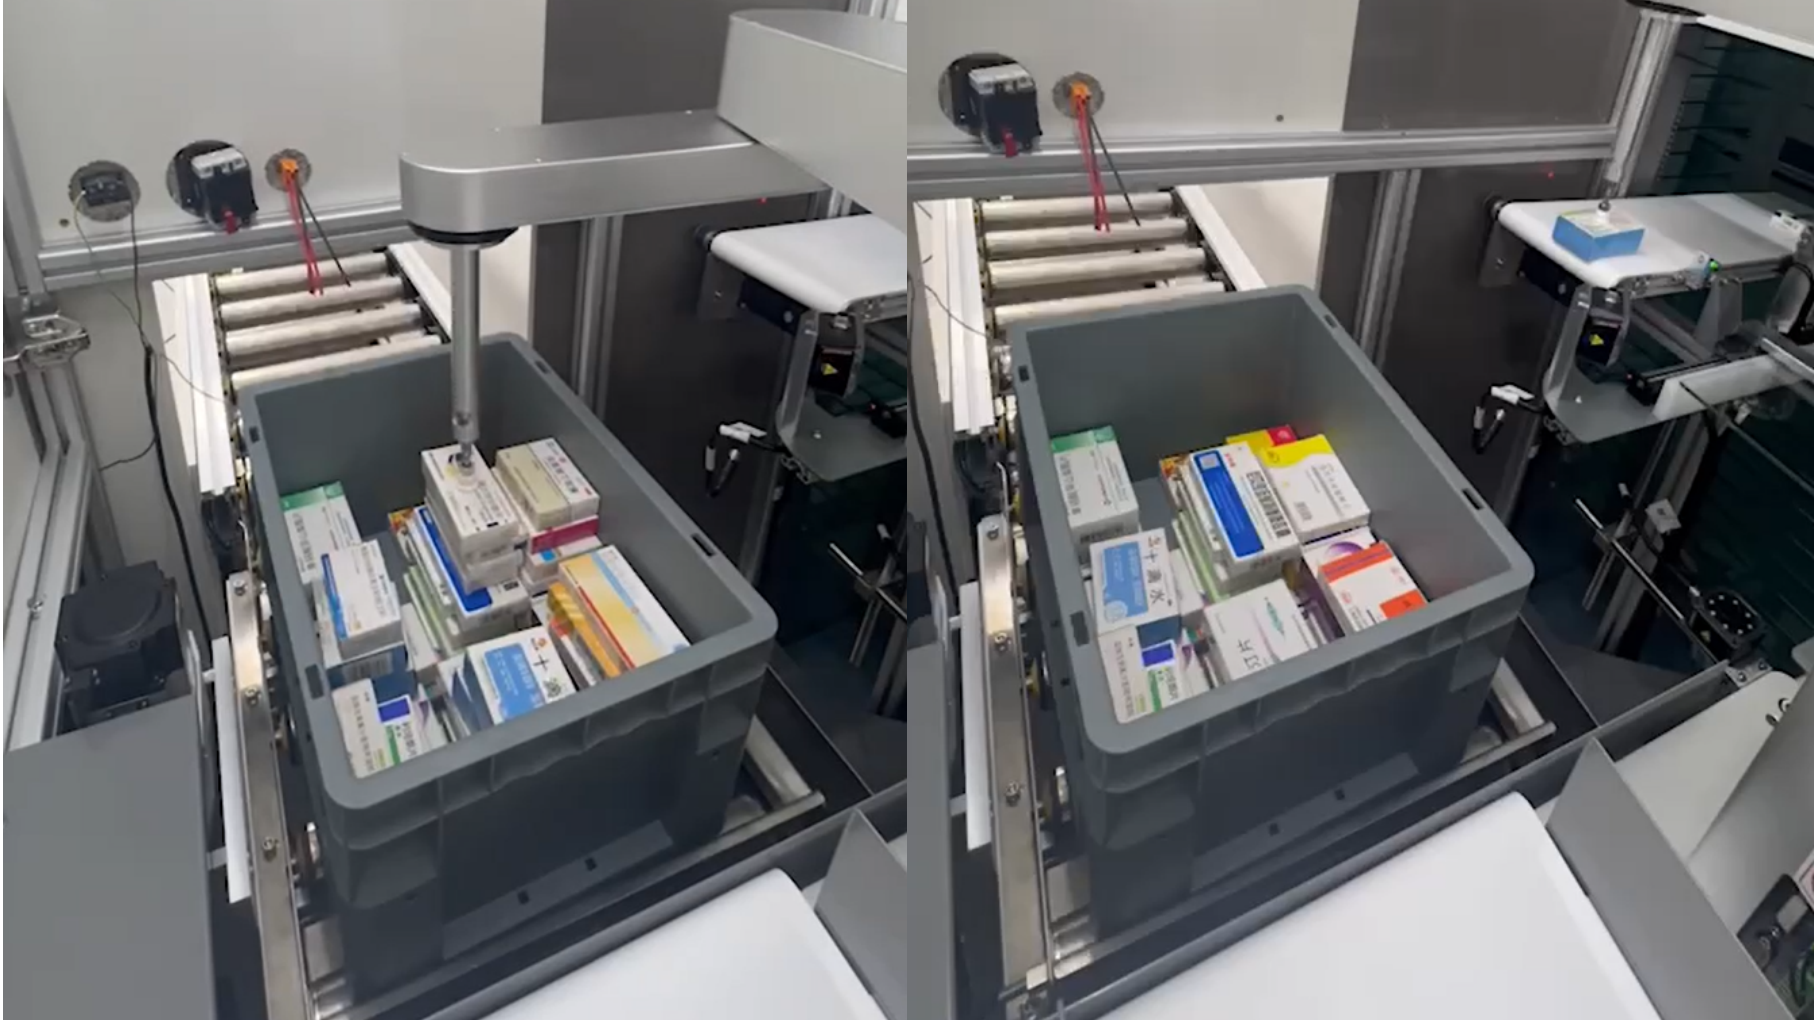
Guides the robot to pick parts and load them into the machine.
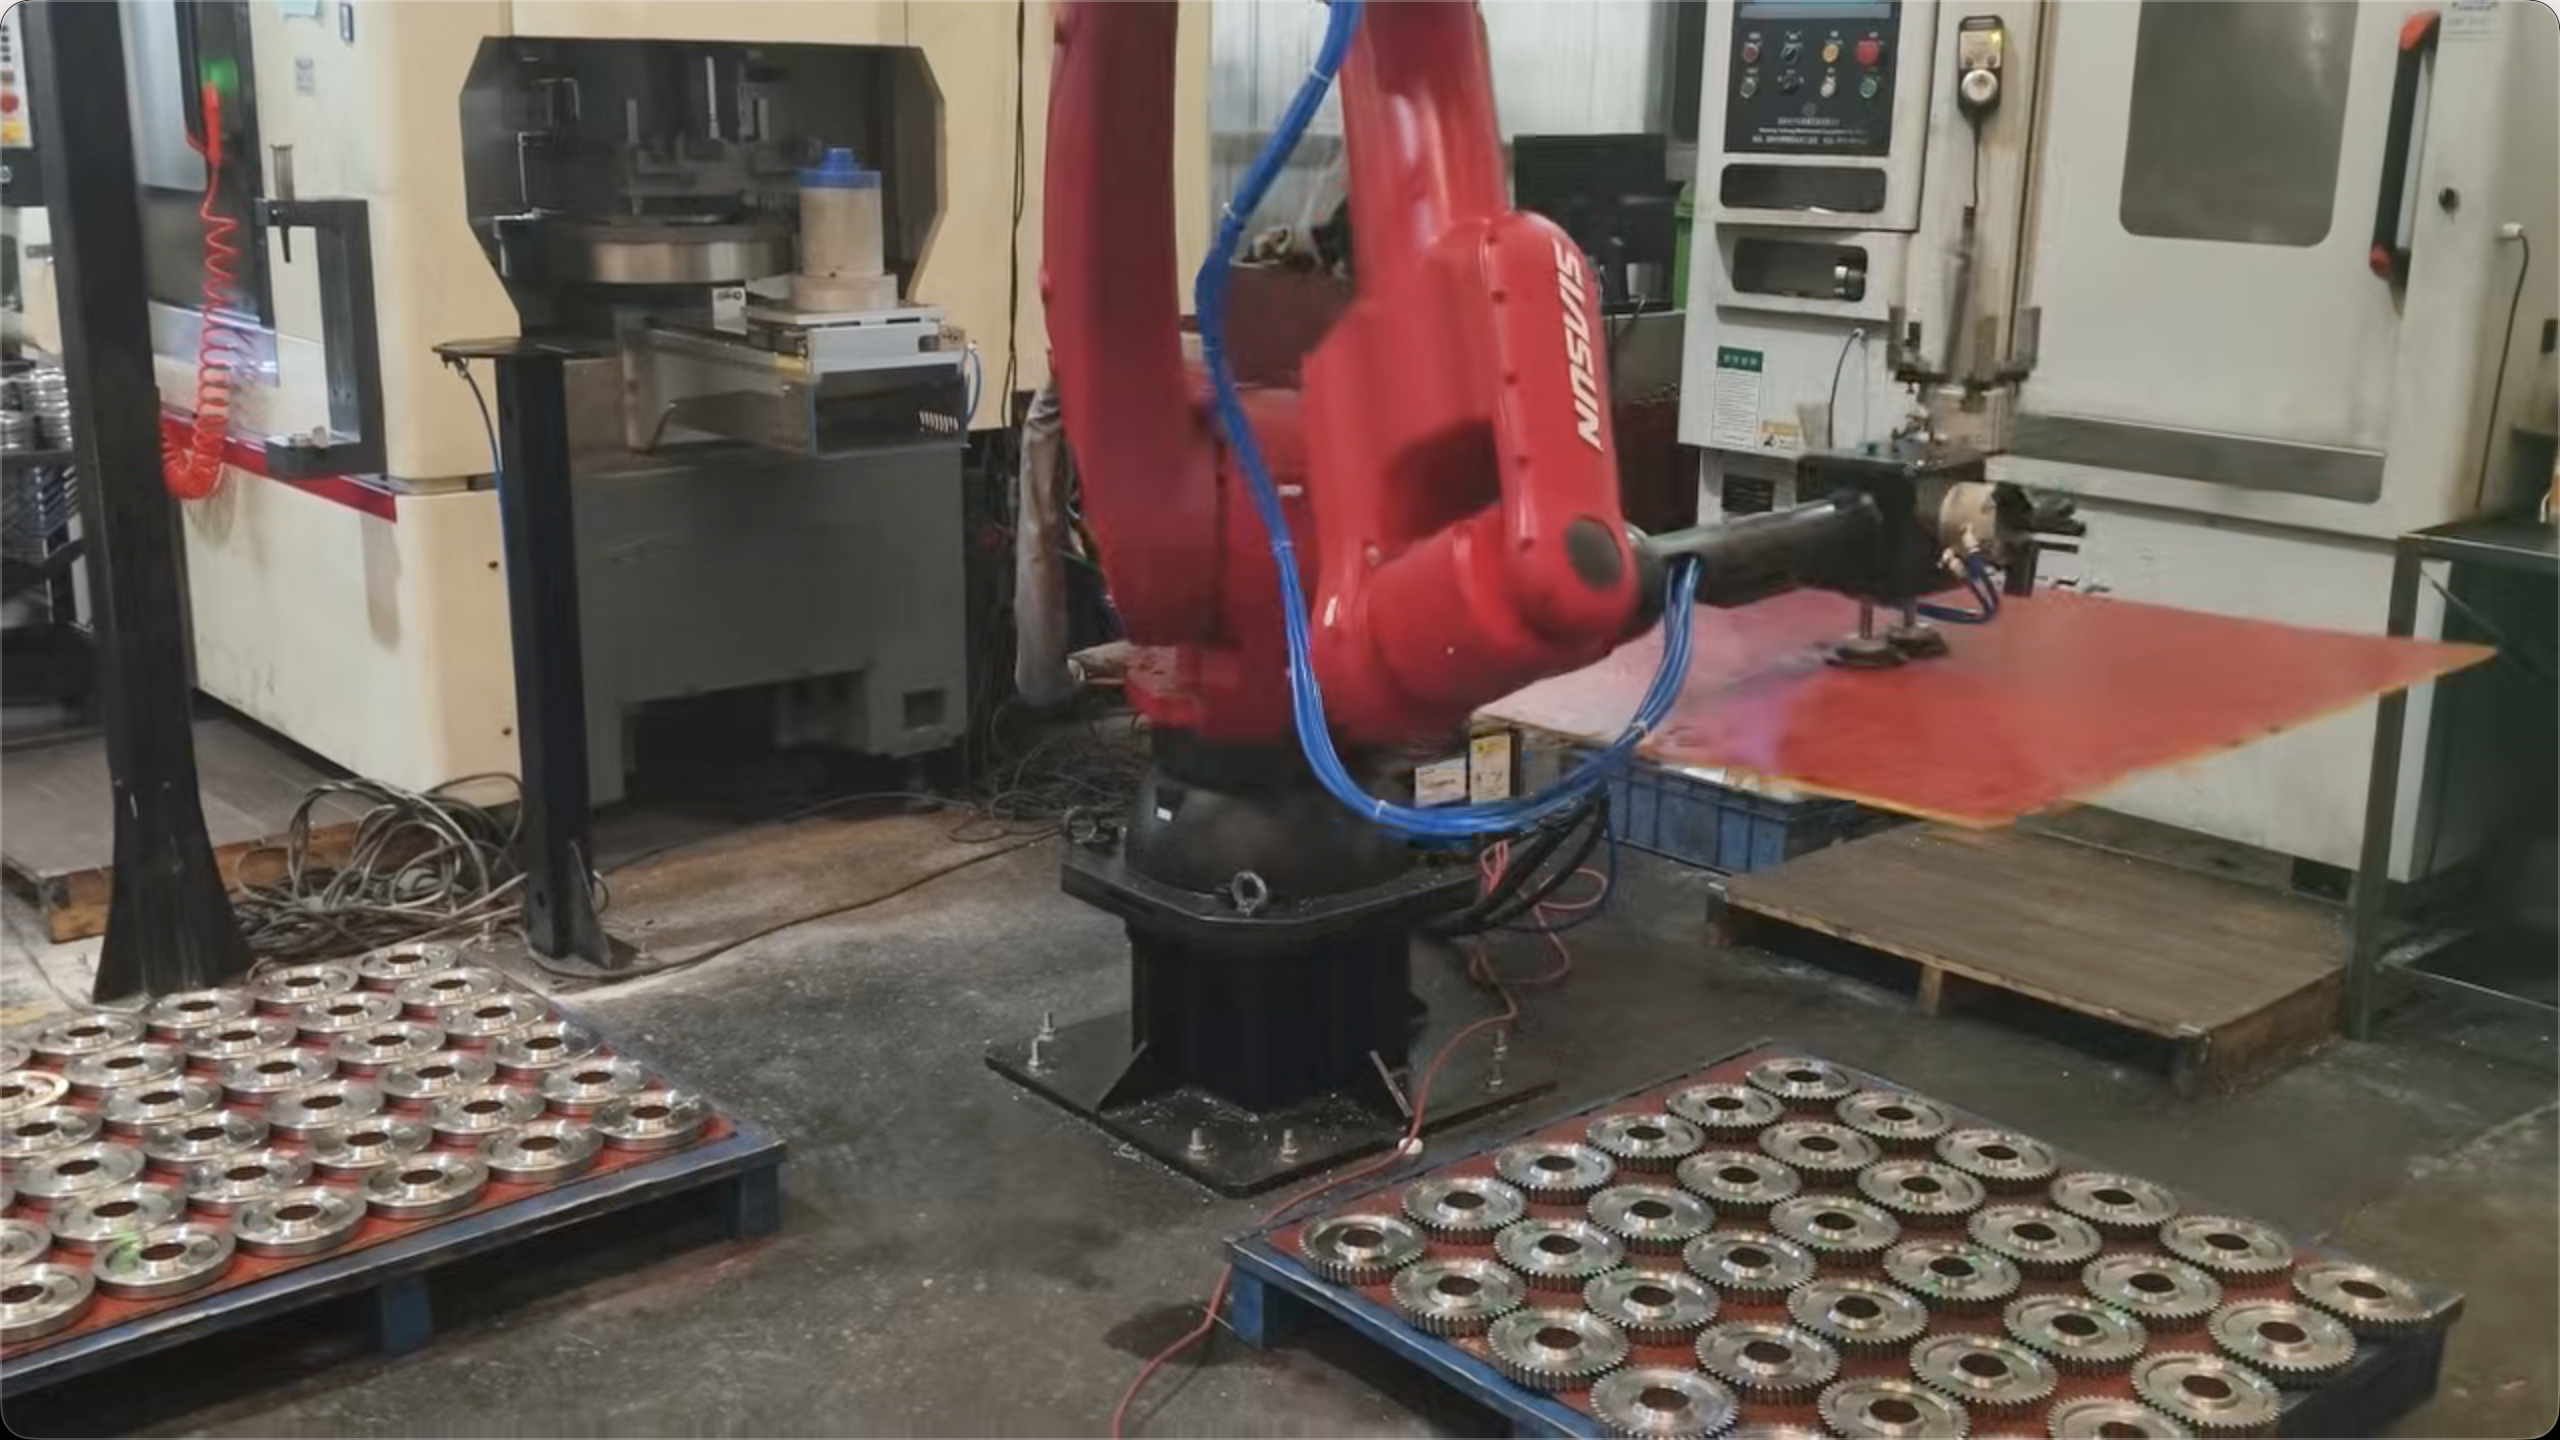
Unloads finished parts after machining, ready for the next step.
A pre-trained model covering common industrial parts and materials, generalizing across part types without per-part training. Built-in palletizing, depalletizing, and bin picking templates, validated in simulation, shorten deployment.
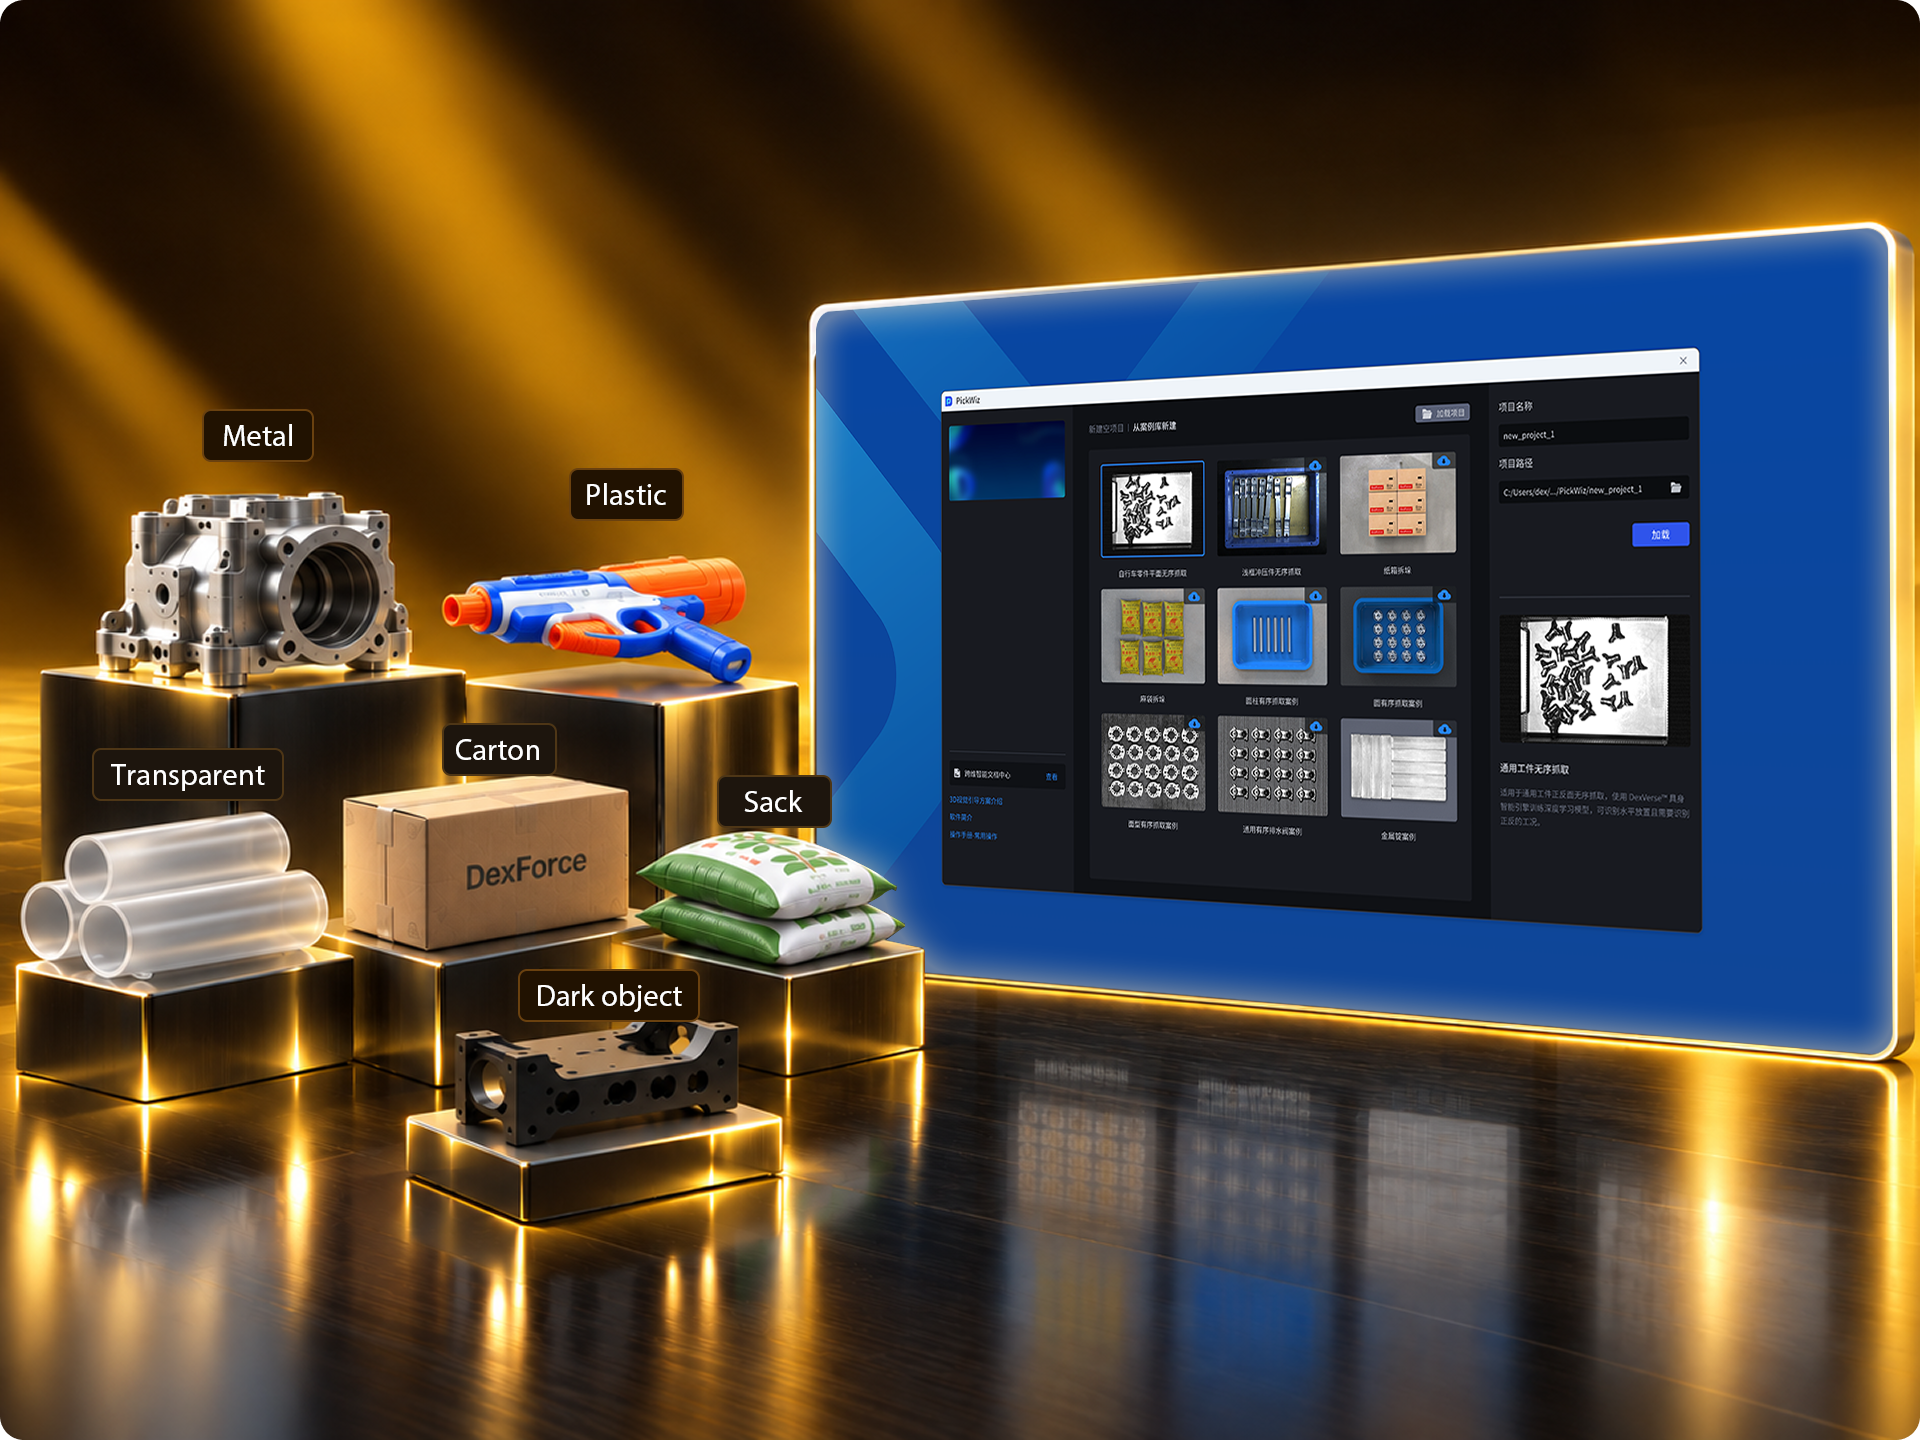
Import a part CAD model and the DexVerse engine trains in a digital twin environment using synthetic data. Covers real-world lighting, shadows, texture, and surface contamination. No photos or manual labeling required.
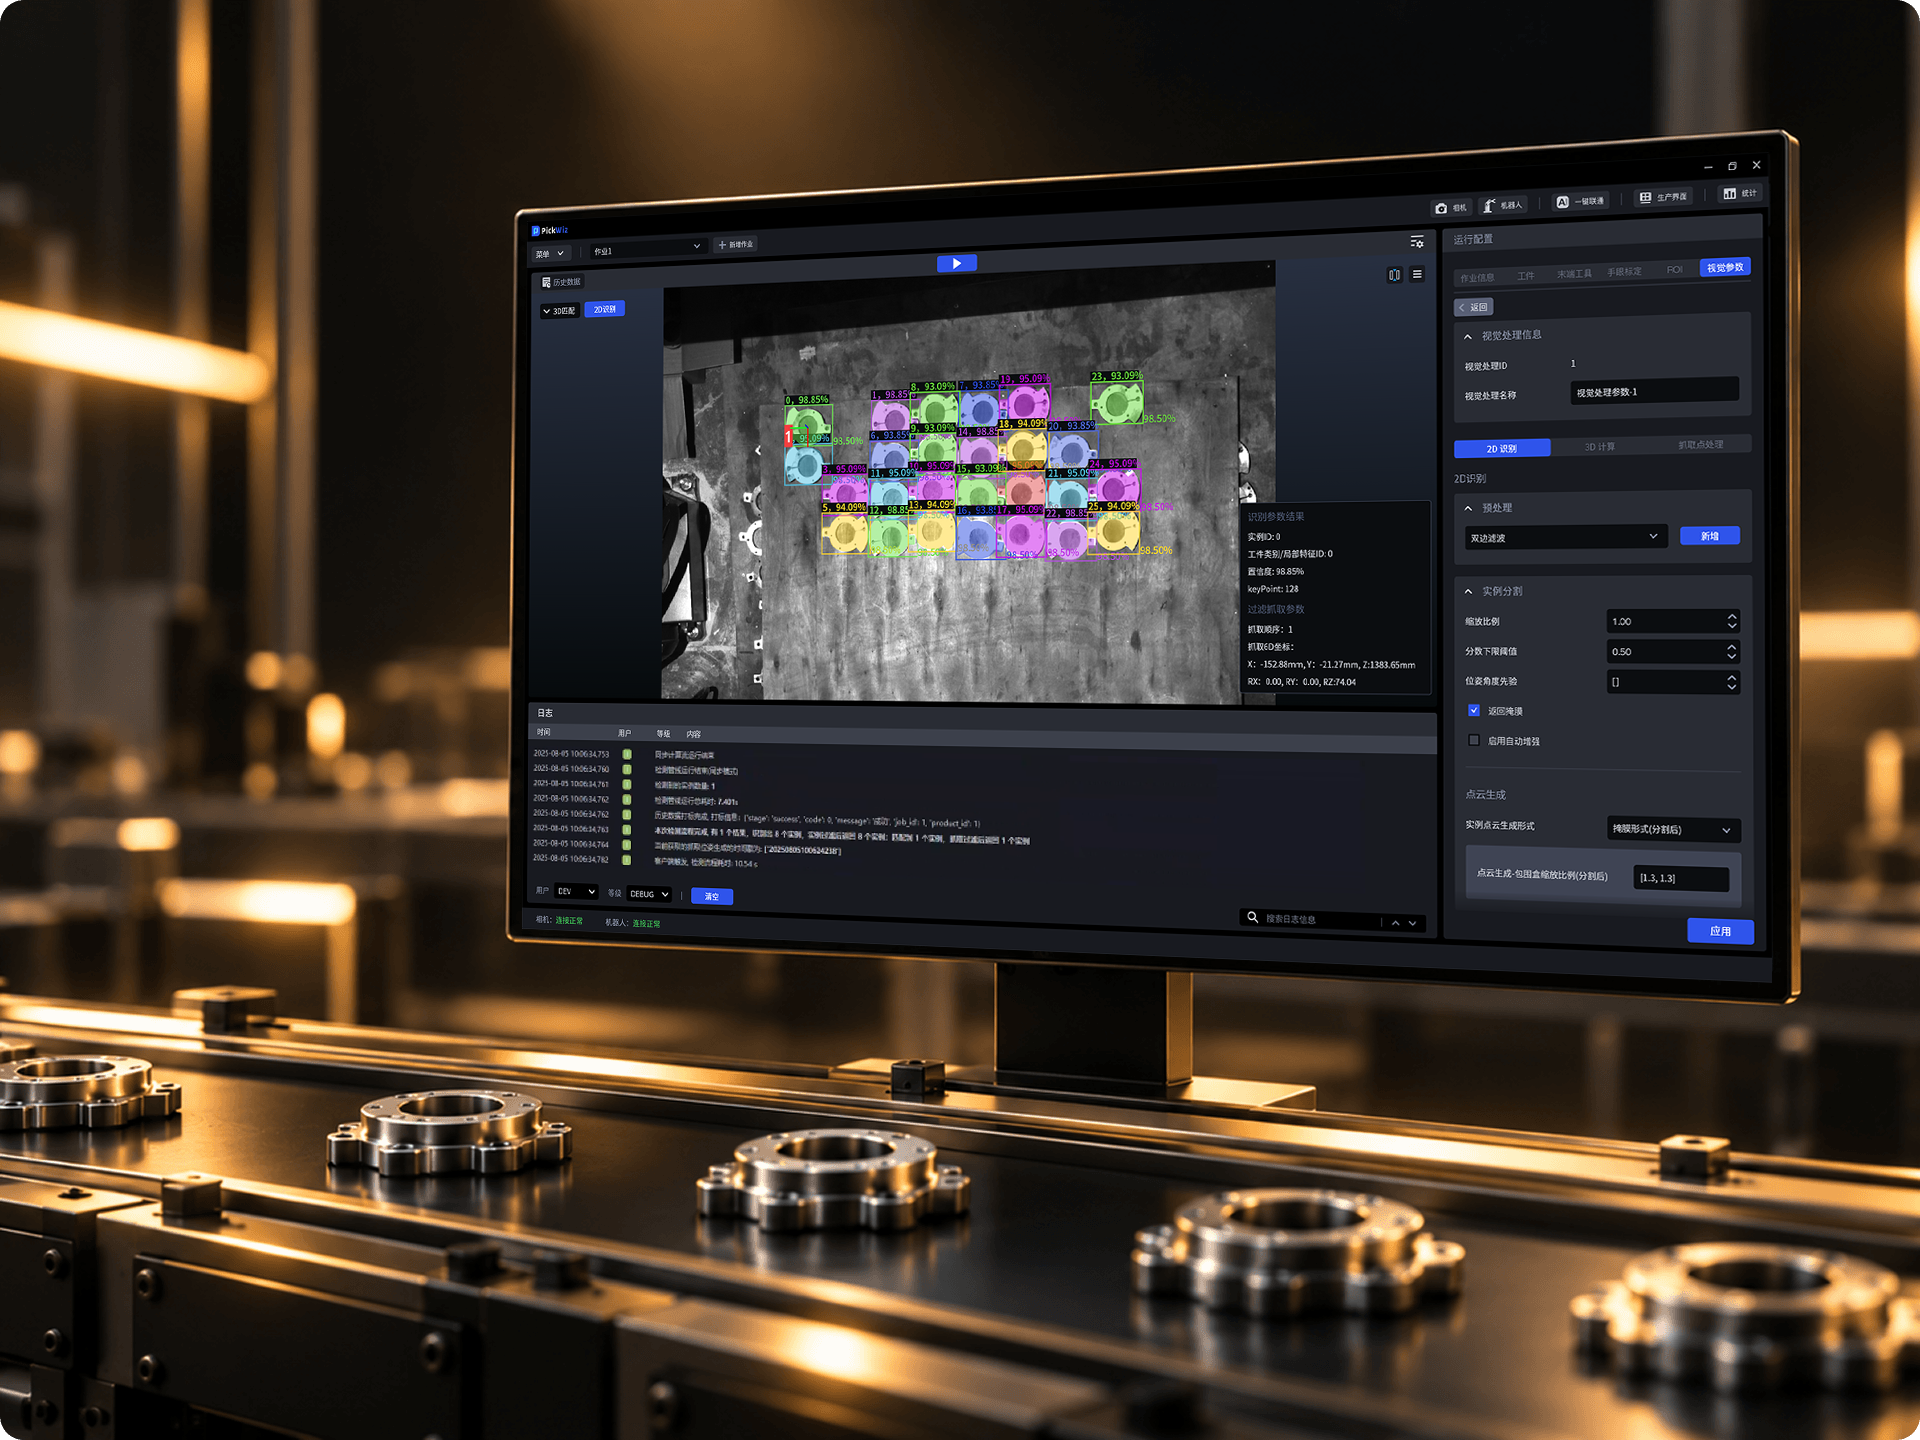
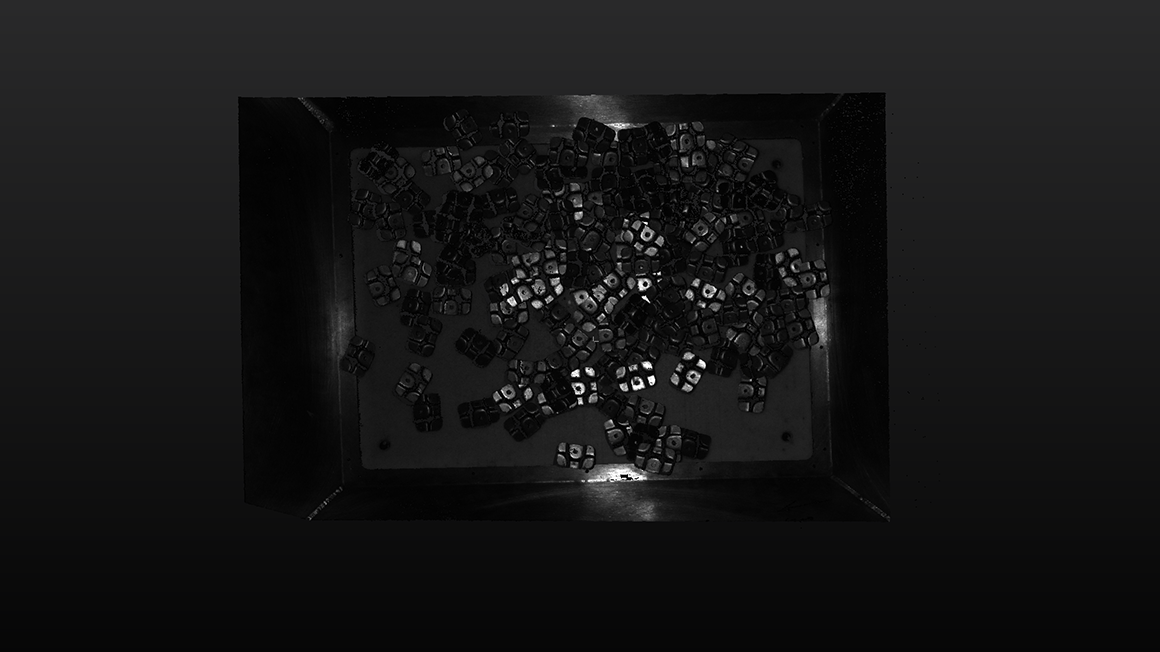
Proprietary ambient light rejection combined with deep learning reduces missed and false recognition in tightly packed parts. Handles overexposure and underexposure, and images reflective, dark, oily, or complex parts reliably.

%

mm
s

hours
| Near field of view (mm) | 965×569 |
|---|---|
| Far field of view (mm) | 2462×1453 |
| Working distance (mm) | 1000–2500 |
| Z-axis repeatability σ (μm) | 80@1.0–2.5m |
| Pixel pitch | 0.55mm@1.0m / 1.37mm@2.5m |
| Acquisition time (s) | 0.5–1.5 |
| Operating systems | Windows、Linux (Ubuntu 20.04) |
| SDK interfaces | C/C++/C#/Python |
XEMA-DCW
XEMA-S
XEMA-LCW