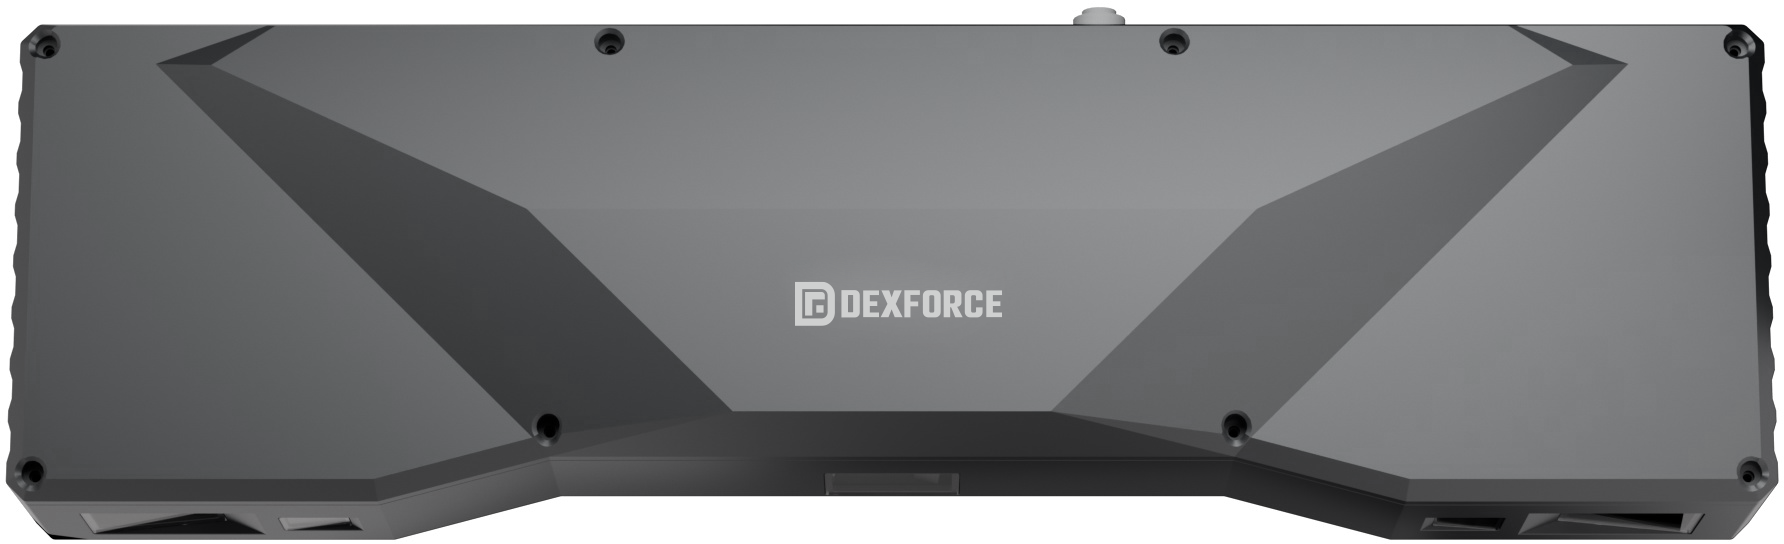

- Capture an entire tray across a 3.5-meter field of view without multiple shots or image stitching.
- Built for large-part handling, such as loading stamped parts into containers.
Redefining robot precision and speed with AI vision
High-Precision Imaging at Ultra-Long Range and Ultra-Wide Field of View
FINCH-W

- Maintain high precision and fast scanning across a wide field of view for reliable guidance of large workpieces.
- Locate a full tray of parts in a single shot, shortening workstation cycles.

- High-density point clouds preserve contours and surface details for reliable recognition.
- A depth-completion algorithm fills in point-cloud data lost to stacked or occluded parts.
Solutions
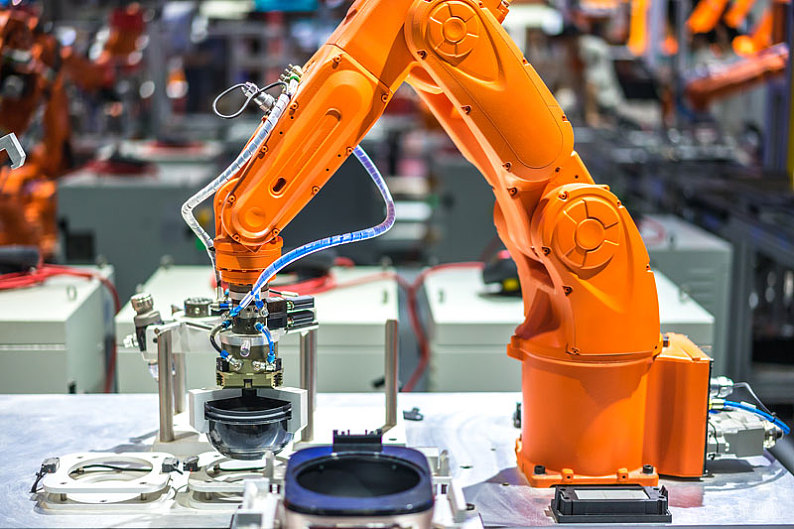
AI + 3D vision guided workpiece handling
AI + 3D vision guide robots to pick randomly stacked or closely packed parts from bins for transfer or further processing. The solution supports workpiece handling in automotive, logistics,construction machinery, and steel manufacturing.
Learn moreAI + 3D vision guided workpiece handling
AI + 3D vision guide robots to pick randomly stacked or closely packed parts from bins for transfer or further processing. The solution supports workpiece handling in automotive, logistics,construction machinery, and steel manufacturing.
Learn more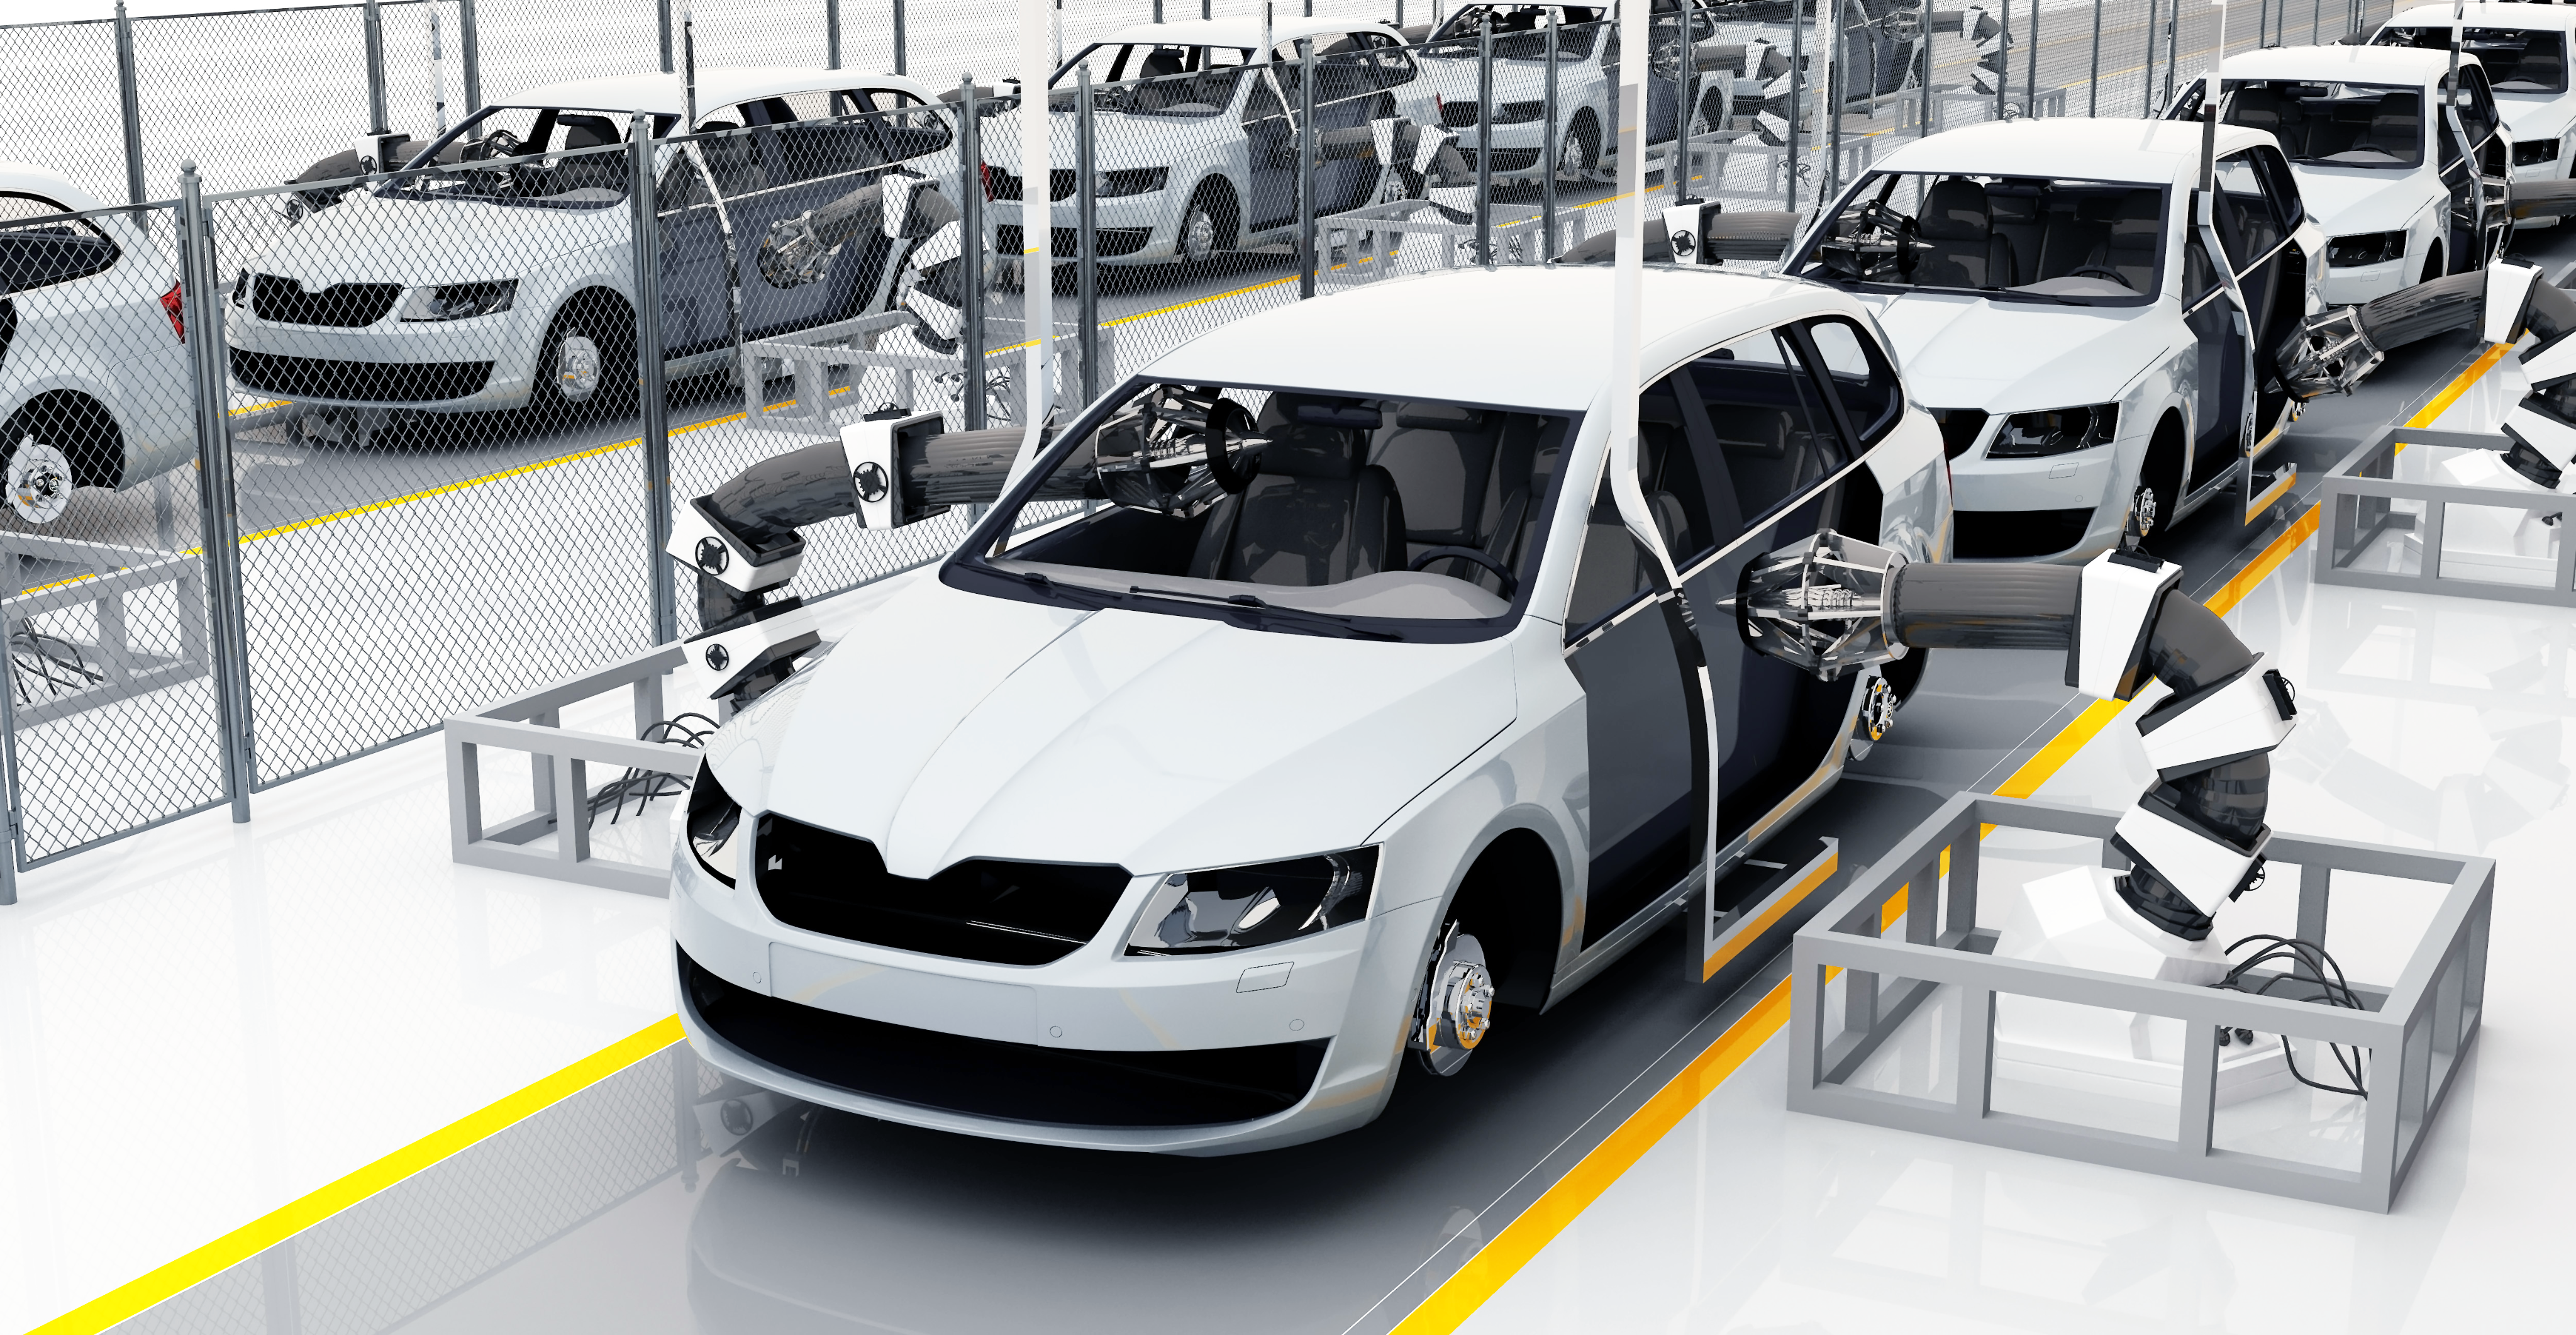
AI + 3D vision guided positioning and assembly
AI and 3D vision identify workpiece position and orientation in real time to guide precise picking, positioning, and assembly. It handles different part sizes and flexible production lines, improving assembly consistency and cutting changeover time.
Learn moreSpecifications
Product model
FINCH-W