o. 1 Worldwide. DexForce Tops the WorldArena Benchmark
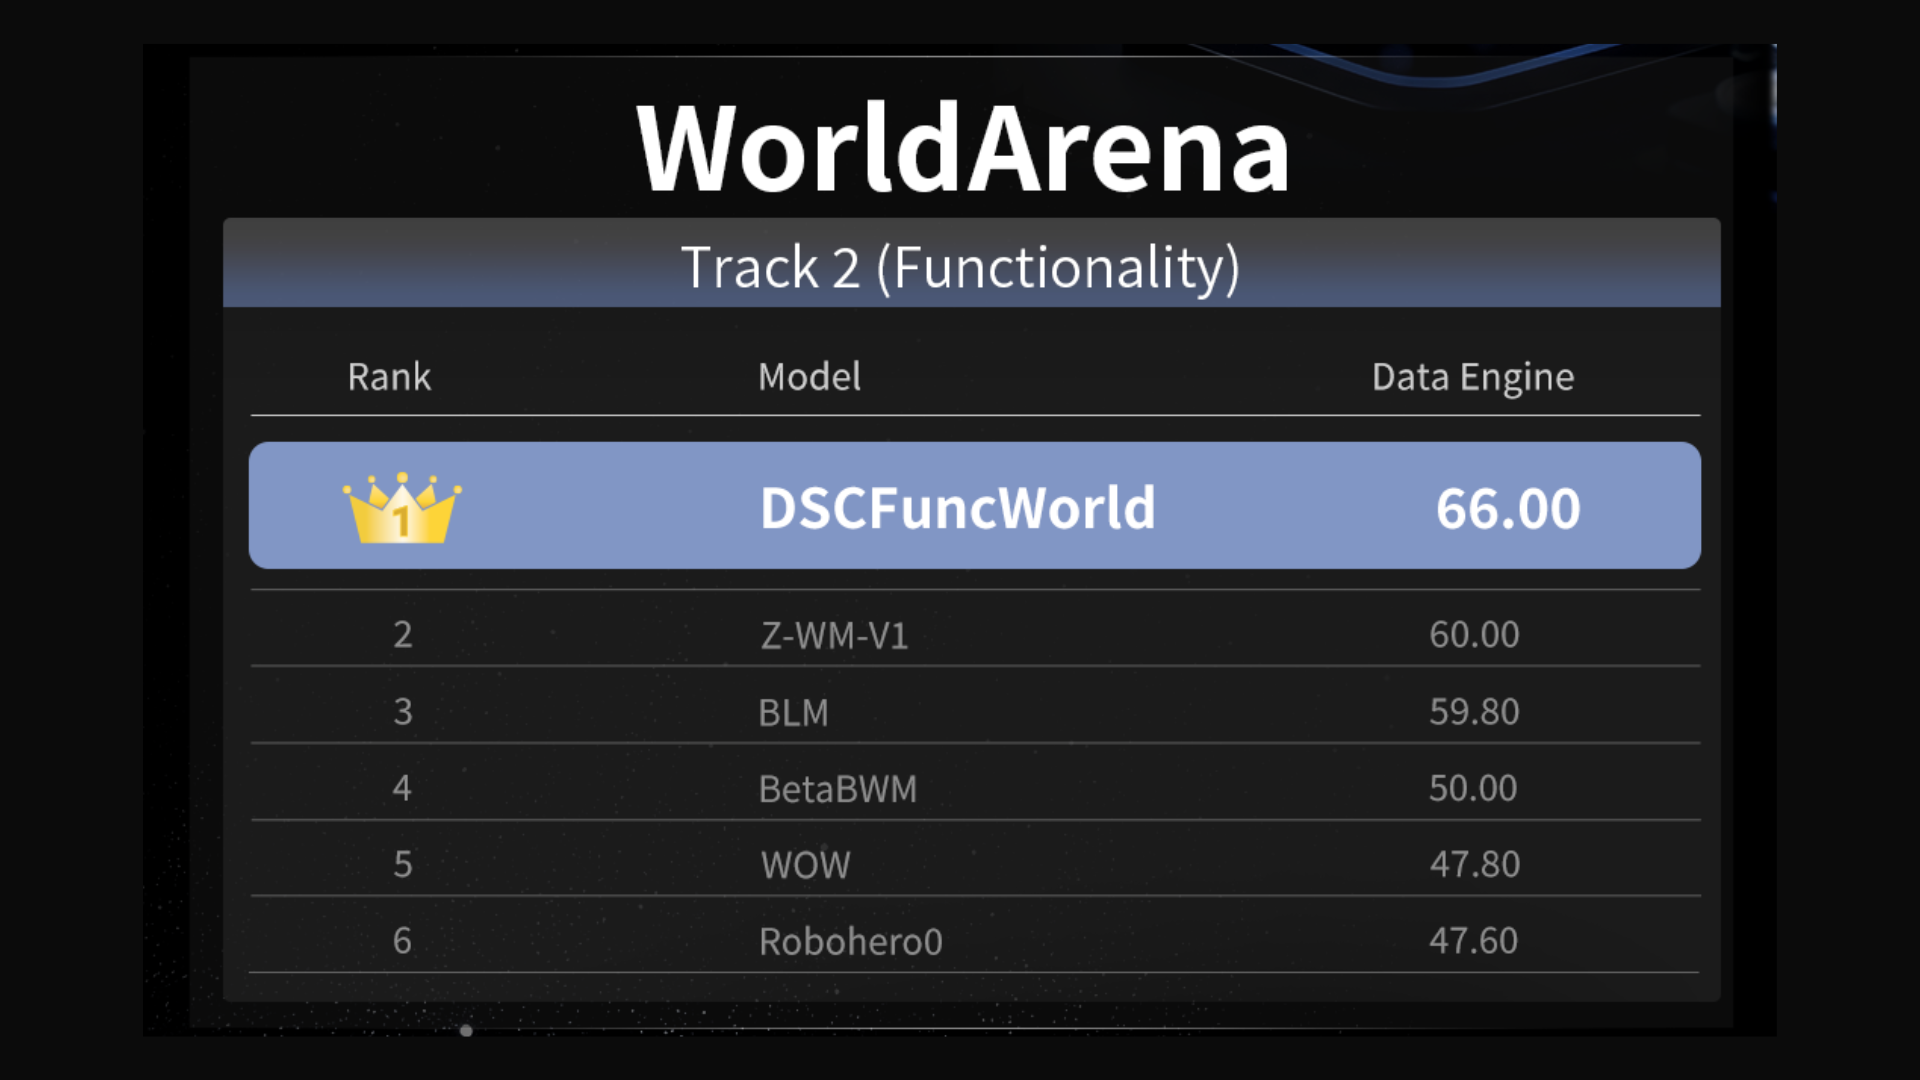
The latest public leaderboard of WorldArena, the authoritative evaluation benchmark for embodied world models, shows that the general embodied world model DSCFuncWorld, independently developed by DexForce Technology, has claimed first place in the world on Track 2 (https://world-arena.ai/). Topping the leaderboard marks international recognition of DexForce in key directions including embodied data generation, world dynamics prediction and robot manipulation models, and further validates the systematic breakthroughs of DexForce along its core technology route toward general embodied AI.
World models are becoming a core direction in the contest among the leading forces of global AI. International technology companies such as NVIDIA and Google continue to push the frontier across Physical AI, robot simulation, environment rollout, synthetic data generation and world foundation models, advancing AI beyond language understanding and visual recognition toward physical world modeling, causal action prediction and agent interaction decision-making. For the embodied AI industry, a world model is no longer just a visual model that generates future frames, but the key technology foundation underpinning robot training, evaluation, planning and generalization.
01 WorldArena heats up as embodied world models enter top-tier global competition
As the authoritative benchmark of the global embodied world model field, WorldArena brings top teams from around the world to compete. The evaluation focuses on world model reasoning, testing in essence how well a robot understands and anticipates the structure, physical laws and dynamic changes of real environments — a yardstick for verifying whether robots understand the real world.
Track 1 (Perception) focuses on overall video quality, assessing visual effects, dynamics, content consistency and physical plausibility, with emphasis on model perception prediction, physical logic and dynamic scene understanding. AgiBot previously took a leading result on this track, underscoring the continued breakthroughs of Chinese embodied AI companies in video generation.
Track 2 (Functionality) focuses on embodied task functionality, testing how well a world model, serving as a data synthesis engine and a carrier for policy evaluation and action planning, supports robot training, evaluation and execution. This track is widely recognized in the industry as the highest “real-combat” bar with the greatest weight, requiring the model to simulate a complete interaction flow from initial observations and text instructions and to output robot training data. It comprehensively tests strength across the full chain of data generation, training and task deployment, and stands asthe core hard metric for judging real-world deployment value.
By topping the global WorldArena Track 2 leaderboard, DSCFuncWorld fully demonstrates that DexForce Technology not only possesses leading world model environment rollout capability, but also the engineering capability to convert rollout results into robot training assets, comprehensively validating the integrated technical strength of the company in embodied data generation, simulation-training closed-loop construction, policy model empowerment and sim-to-real deployment.
Topping the chart was no one-off leaderboard run, but ratherthe result of sustained accumulation by DexForce Technology across its world model and embodied data systems. For the WorldArena Track 2 Data Engine task, DexForce built on its self-developed DexWorldModel(https://dexforce.com/technical-report/#/DexWorldModel) for the upgrade: the model originally emphasized modeling future world states in semantic feature spaces such as DINO, with robust representation of textures, object relations and environments; after a simple adaptation it can directly generate videos, further proving its capability as a data engine and policy evaluator.
The lead on the Data Engine task comes down to one core requirement: generated data must be truly “trainable, transferable and executable”. On one hand, videos generated by the world model must remain highly consistent with actual task execution, so that policy capabilities trained on generated data transfer into the evaluation environment; on the other hand, generated trajectories cannot merely look plausible — they must also be operable and executable. In prior work such as EVA (EVA: Aligning Video World Models with Executable Robot Actions via Inverse Dynamics Rewards; https://eva-project-page.github.io/) DexForce has continuously strengthened the executable alignment of world-model-generated trajectories, bringing the futures the model generates closer to motion paths that real robots can actually complete.
At the same time, DexForce Technology keeps accumulating reachable trajectories and diverse task samples on the embodied data side, improving the coverage and effectiveness of generated data for policy training. EmbodiChain (https://github.com/DexForce/EmbodiChain), a representative of the data infrastructure DexForce has made public, covers asset generation, scene layout, trajectory sampling, failure recovery, data feedback and online data streams, continuously supplying world model training with richer, more physically plausible and more task-relevant data sources.
This also explains why DexForce leads on the Track 2 Data Engine task: what the track examines is not video generation quality itself, but whether generated data can genuinely raise the success rate of robot policies on embodied tasks. DSCFuncWorld ranking first on the global public leaderboard validates the closed-loop capability of DexForce from data construction and world modeling to policy training, and further signals that world models are moving from “watchable” to “usable”.